Settings
 Fast Delivery
DigiKey customers in the United States can choose from a wide range of fast, reliable delivery options, with shipping rates starting as low as $4.99.
 Payment Types
Credit account for qualified institutions and businesses
Payment in Advance by Wire Transfer


 Marketplace Product
More Products From Fully Authorized Partners
Average Time to Ship 1-3 Days. Please see product page, cart, and checkout for actual ship speed.
Extra Ship Charges May Apply
For more information visit Help & Support

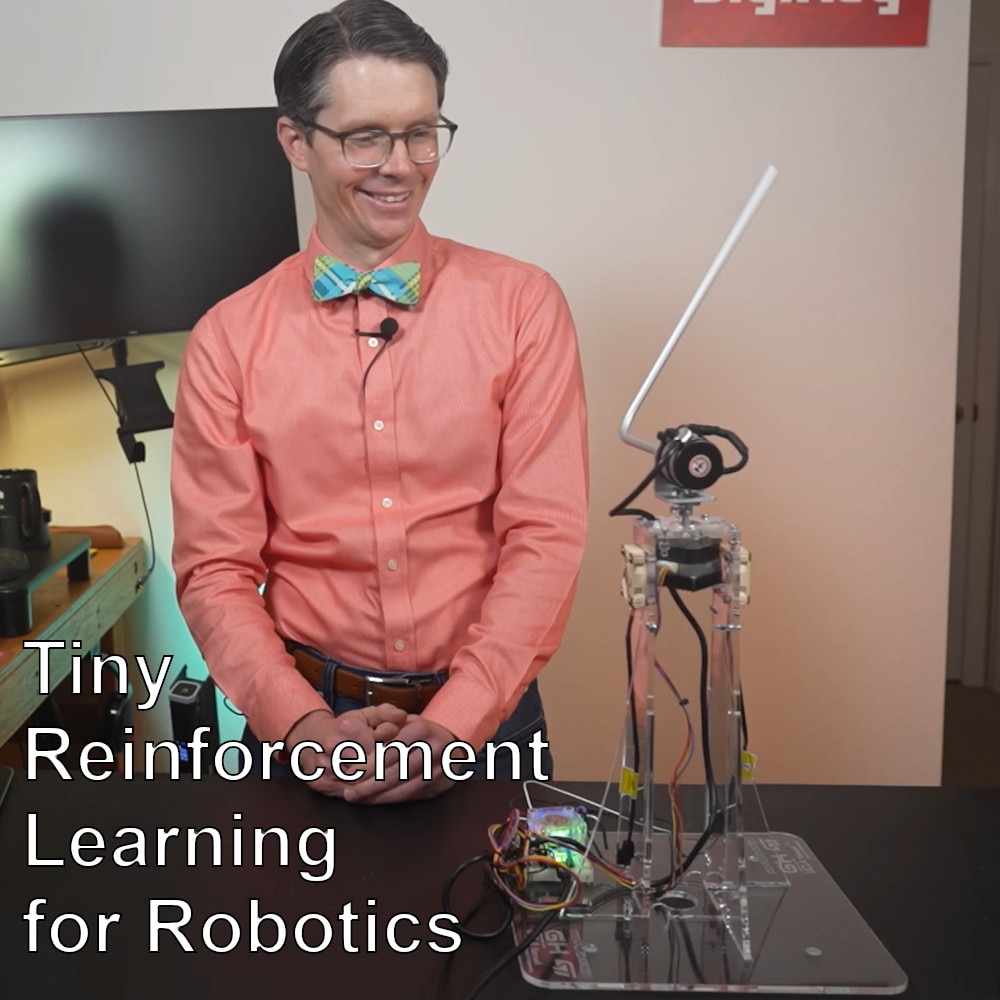
This project demonstrates using reinforcement learning to solve the swing-up problem on an inverted pendulum
In this tutorial, we demonstrate how to manually tune a PID controller.
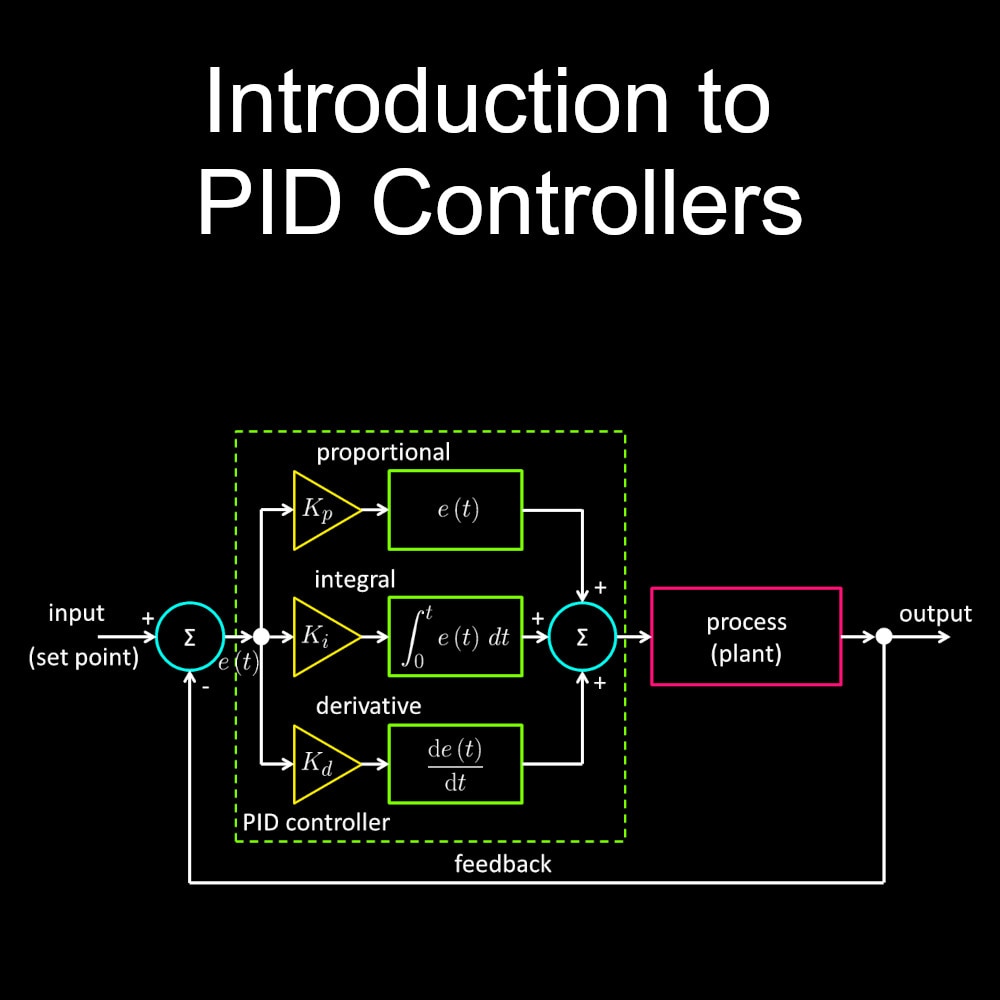
In this post, we cover the basic theory behind PID controllers. PID stands for “Proportional, Integral, Derivative," and they are commonly used in industrial settings to control various processes.

Thank you!
Keep an eye on your inbox for news and updates from DigiKey!
Please enter an email address
Please accept the checkbox